Simon Sagmeister

Hi, I'm

Simon Sagmeister

I

Team Lead and Researcher with 4+ years of experience building real-world autonomous driving systems. Passionate about reliable, high-performance, and modular robotics software, AI, simulation, and motion control.

Highlights

Selected milestones, media coverage, and projects from recent years

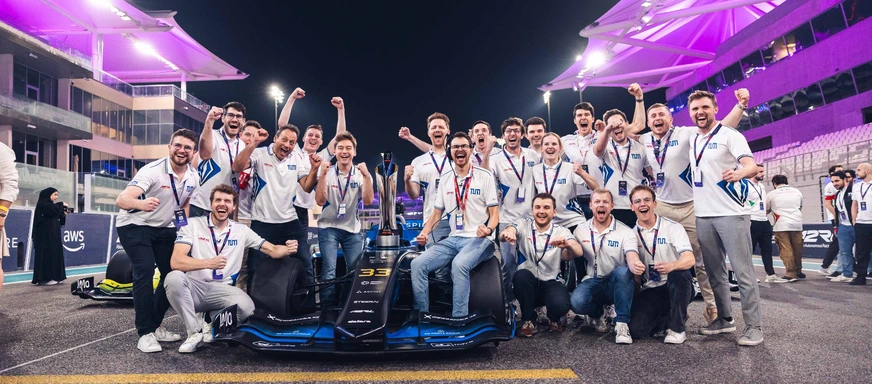
TUM Autonomous Motorsport — A2RL Championship Wins

  • Back-to-back A2RL champions (2024 and 2025) at the Yas Marina Circuit
  • Led a team of 14 doctoral researchers across perception, planning, control, and integration
  • Incident-free competitive operation across extended, high-intensity race weeks
Approaching Human Performance in Autonomous Racing

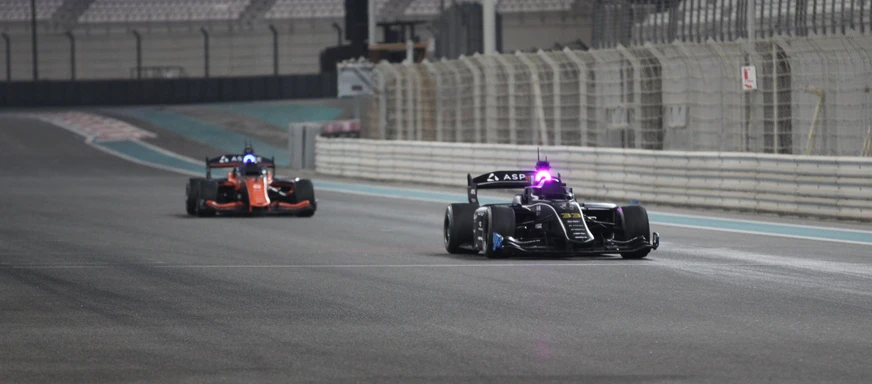
Approaching Human Performance in Autonomous Racing

  • Raced former F1 driver Daniil Kvyat head-to-head at the Yas Marina Circuit — setting an autonomous lap record of 58.2 s, only 0.7 s off his 57.5 s
  • First high-speed autonomous overtakes executed wheel-to-wheel in competition
  • Centimeter-precise cornering at over 250 km/h on a Formula 1 circuit
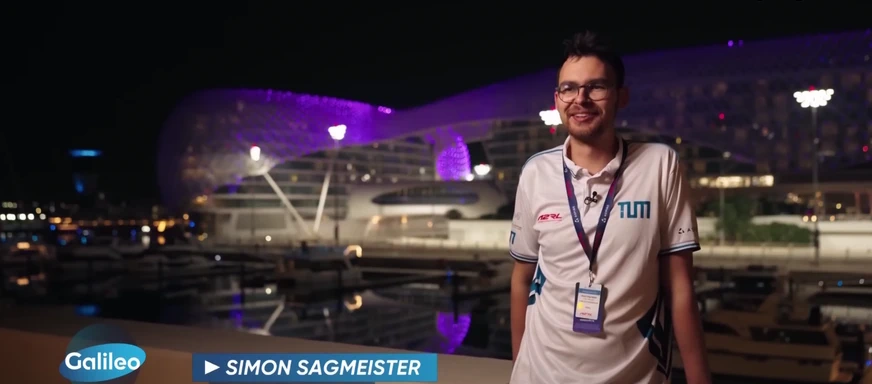
Galileo Feature — Bringing Autonomous Racing to a Broad Audience

Galileo Feature — Bringing Autonomous Racing to a Broad Audience

  • Featured on Galileo, one of Germany’s best-known science and technology TV formats
  • Carried the work beyond the research community to a broad public audience
  • See more of the team on the TUM Autonomous Motorsport website
rslcpp

rslcpp

  • Runs rclcpp::Node components in a single-process simulation loop
  • Explicit time control makes runs reproducible across hardware platforms
  • Enables large-scale automated testing using ROS 2 without modification
C++ ROS 2 CMake
Open Car Dynamics

Open Car Dynamics

  • Modular simulation library comprising submodules for drivetrain, steering, and vehicle dynamics
  • Written in modern C++, with optional Python, ROS 2, and MATLAB integrations
  • Built for accurate and efficient simulation under real-time constraints
C++ CMake Python ROS 2
TSL

TSL

  • Low-overhead logging for large sets of numeric debug and telemetry signals
  • C++ and Python APIs over one analysis-friendly output format
  • No custom serialization format, so downstream tooling keeps working
C++ Python ROS 2 CMake

Research & Tech Stack

Research focus areas together with the tools I use in practice

Research Focus

Simulation
Control
Modularity
Evaluation

Programming & Scientific Computing

C++
Python
IEC 61131-3
MATLAB

Frameworks & Tools

ROS 2
CMake
PyTorch
pytest

Development & Deployment

Docker
Ubuntu
Git
CI/CD

Other Tools

PTC Creo
CATIA V5
LaTeX
Microsoft Office

My Publications

2026 Preprint Featured
arXiv

Beyond the Plane: Coupling Planar Vehicle Dynamics with Three-Dimensional Road Geometry

Simon Sagmeister, Phillip Pitschi, Nico Haja, Markus Lienkamp
2026 Journal article Featured
IEEE Robotics and Automation Practice

RSLCPP - Deterministic Simulations Using ROS 2

Simon Sagmeister, Marcel Weinmann, Phillip Pitschi, Markus Lienkamp
2026 Preprint
arXiv

Head-to-Head Autonomous Racing at the Limits of Handling in the A2RL Challenge

Simon Hoffmann
Equal contribution
, Simon Sagmeister
Equal contribution
, Tobias Betz, Joscha Bongard, Sascha Büttner, Dominic Ebner, Daniel Esser, Georg Jank, Sven Goblirsch, Alexander Langmann, Maximilian Leitenstern, Levent Öğretmen, Phillip Pitschi, Ann-Kathrin Schwehn, Cornelius Schröder, Marcel Weinmann, Frederik Werner, Boris Lohmann, Johannes Betz, Markus Lienkamp
2025 Conference paper
2025 IEEE Intelligent Vehicles Symposium

A Quasi-Steady-State Black Box Simulation Approach for the Generation of g-g-g-v Diagrams

Frederik Werner, Simon Sagmeister, Mattia Piccinini, Johannes Betz
2025 Conference paper
2025 IEEE Intelligent Vehicles Symposium

Approaching Current Challenges in Developing a Software Stack for Fully Autonomous Driving

Simon Sagmeister, Simon Hoffmann, Tobias Betz, Dominic Ebner, Daniel Esser, Markus Lienkamp
2025 Conference paper
2025 IEEE Intelligent Vehicles Symposium

Longitudinal Control for Autonomous Racing with Combustion Engine Vehicles

Phillip Pitschi, Simon Sagmeister, Sven Goblirsch, Markus Lienkamp, Boris Lohmann
2025 Journal article
IEEE Access

End-to-End Latency Optimization for Containerized ROS 2 Autonomous Driving Software

Tobias Betz, Harun Teper, Dominic Ebner, Maximilian Leitenstern, Simon Sagmeister, Marcel Weinmann, Jian-Jia Chen, Markus Lienkamp
2024 Conference paper Featured
2024 IEEE Intelligent Vehicles Symposium

Analyzing the Impact of Simulation Fidelity on the Evaluation of Autonomous Driving Motion Control

Simon Sagmeister, Panagiotis Kounatidis, Sven Goblirsch, Markus Lienkamp
2023 Preprint
arXiv

EDGAR: An Autonomous Driving Research Platform — From Feature Development to Real-World Application

Phillip Karle, Tobias Betz, Marcin Bosk, Felix Fent, Nils Gehrke, Maximilian Geisslinger, Luis Gressenbuch, Philipp Hafemann, Sebastian Huber, Maximilian Hübner, Sebastian Huch, Gemb Kaljavesi, Tobias Kerbl, Dominik Kulmer, Tobias Mascetta, Sebastian Maierhofer, Florian Pfab, Filip Rezabek, Esteban Rivera, Simon Sagmeister, Leander Seidlitz, Florian Sauerbeck, Ilir Tahiraj, Rainer Trauth, Nico Uhlemann, Gerald Würsching, Baha Zarrouki, Matthias Althoff, Johannes Betz, Klaus Bengler, Georg Carle, Frank Diermeyer, Jörg Ott, Markus Lienkamp
2021 Book section
Berichte aus dem μ-Club 2020

The Relevance of Gas Solubility in Brake Fluids

Andreas Eisele, Simon Sagmeister
2019 Conference paper
ASME/BATH Symposium on Fluid Power and Motion Control

Air Solubility Measurements and Modeling of Brake Fluids

Andreas Eisele, Simon Sagmeister, Michael Schneider, Markus Lienkamp

Get In Touch

Always glad to hear about research collaborations, new opportunities, or questions about the work. Email and LinkedIn both reach me — whichever you prefer.

Find me on

Or send me an email

✓ Copied to clipboard!